Model a desk robot arm: the wrist
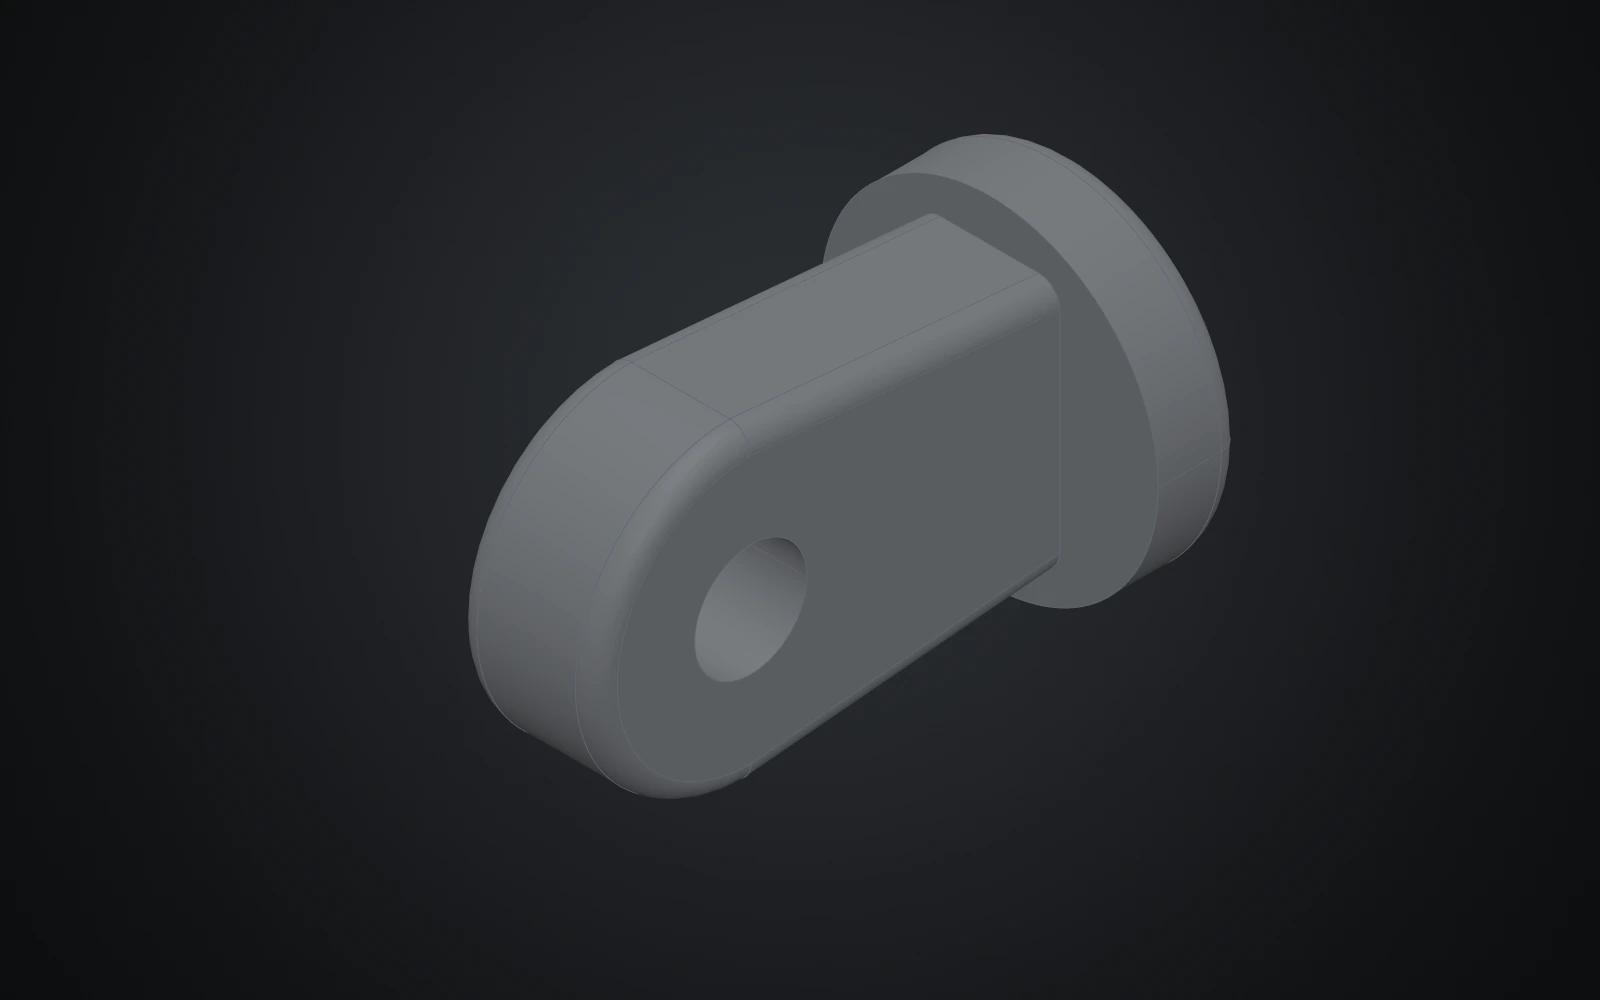
The wrist is small and quick: an extruded knuckle, a flange raised on one of its faces, and the pin it turns on.
Each step shows the Designer as you make it: a feature's dialog filled in with the step's values, with the tutorial card ringing OK, or what the step made. The first time a command appears, a picture shows where it is. The step numbers match the card's in Help > Tutorials.
-
New part, from File > New part: name Wrist.
The wrist is a knuckle with a flange: extrude its outline, add a round boss on its face, round the rims and drill the pin hole.
-
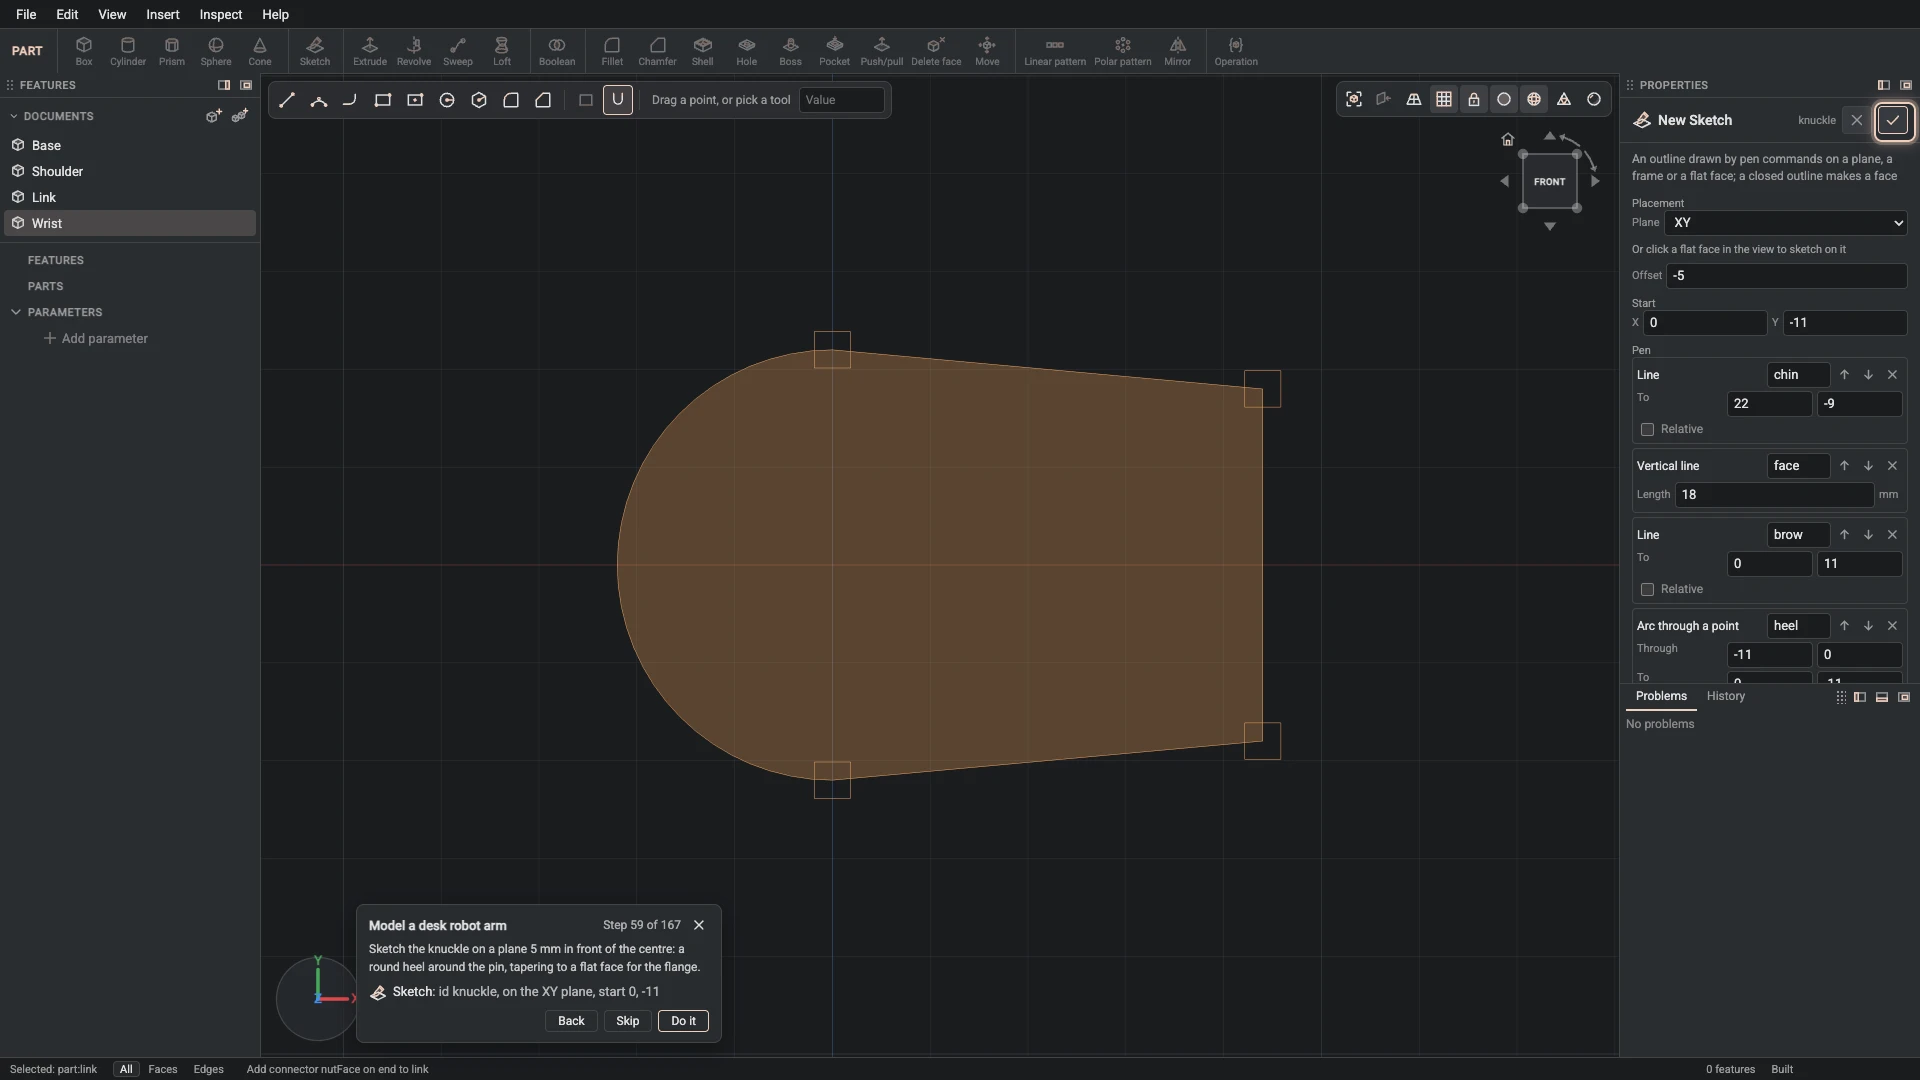
Sketch, from Insert > Sketch: id knuckle, on the XY plane, start 0, -11.
Sketch the knuckle on a plane 5 mm in front of the centre: a round heel around the pin, tapering to a flat face for the flange.
-
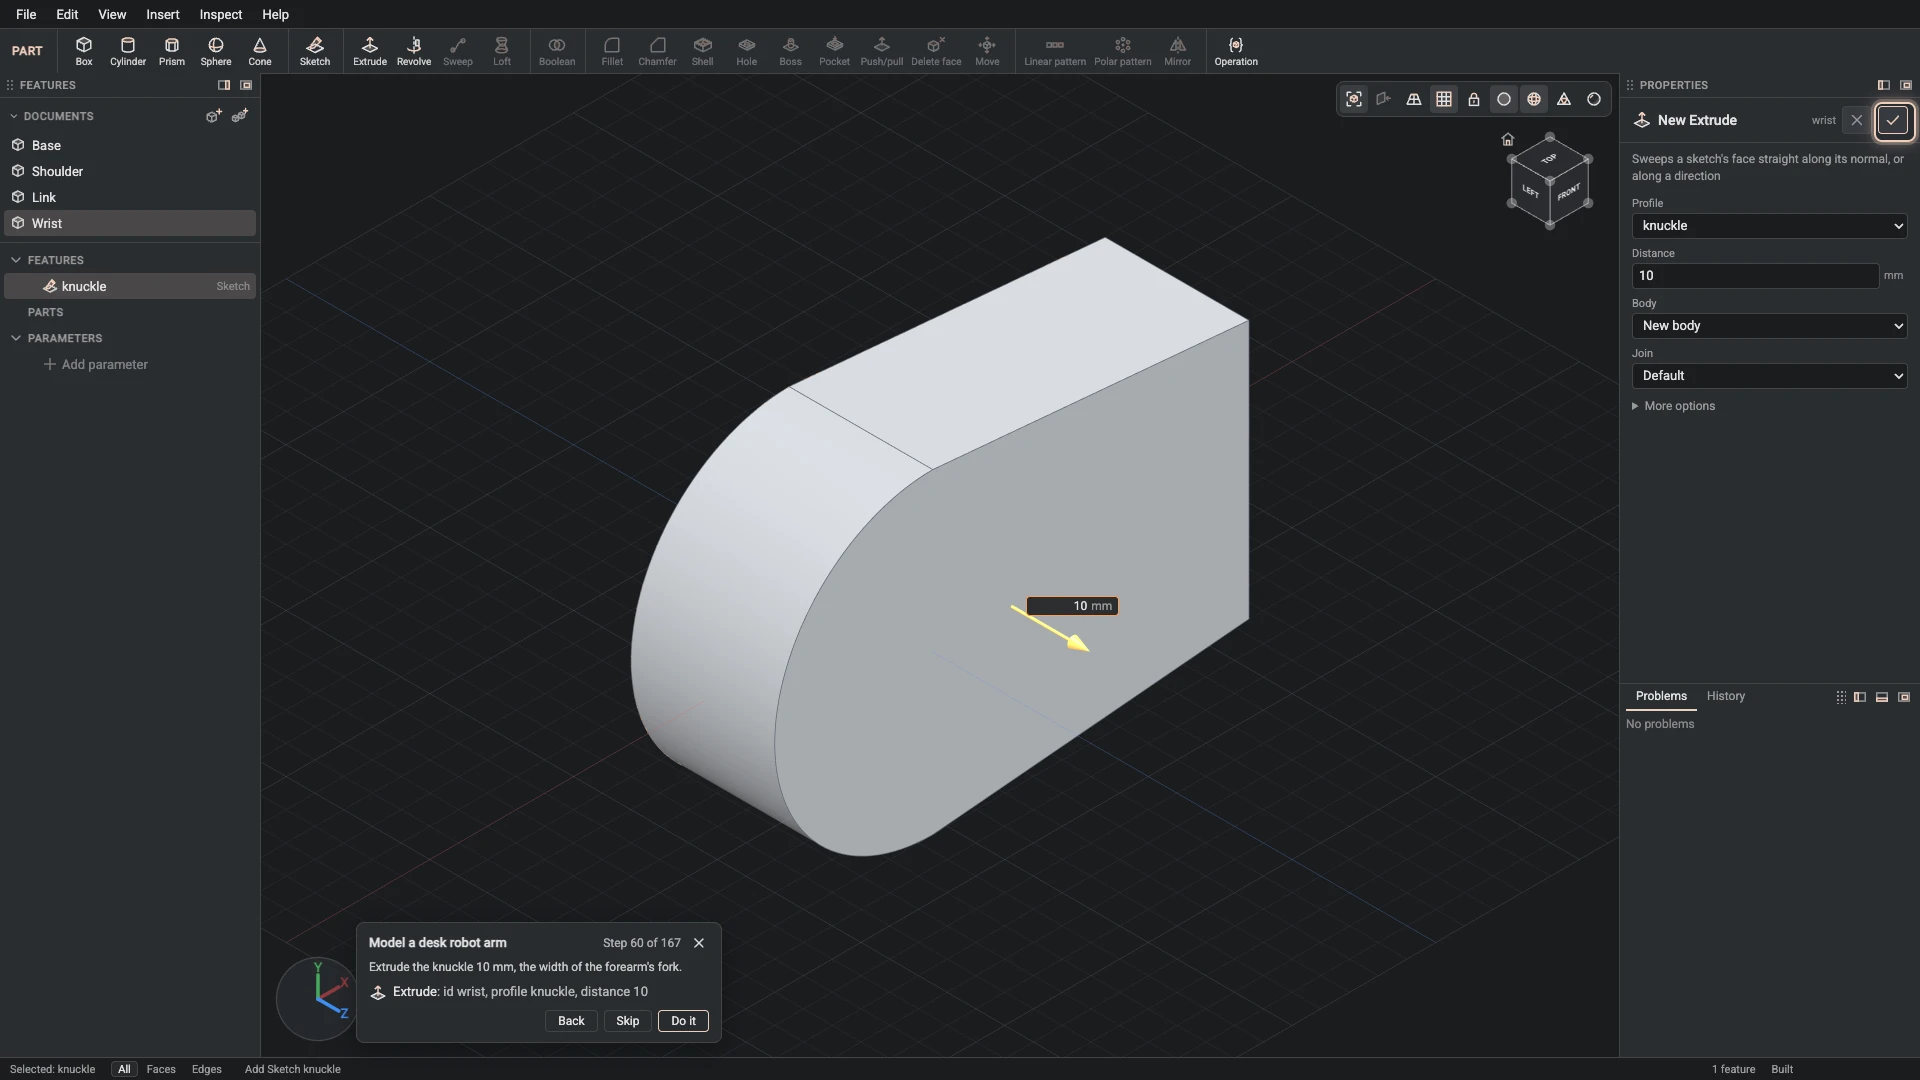
Extrude, from Insert > Extrude: id wrist, profile knuckle, distance 10.
Extrude the knuckle 10 mm, the width of the forearm's fork.
-
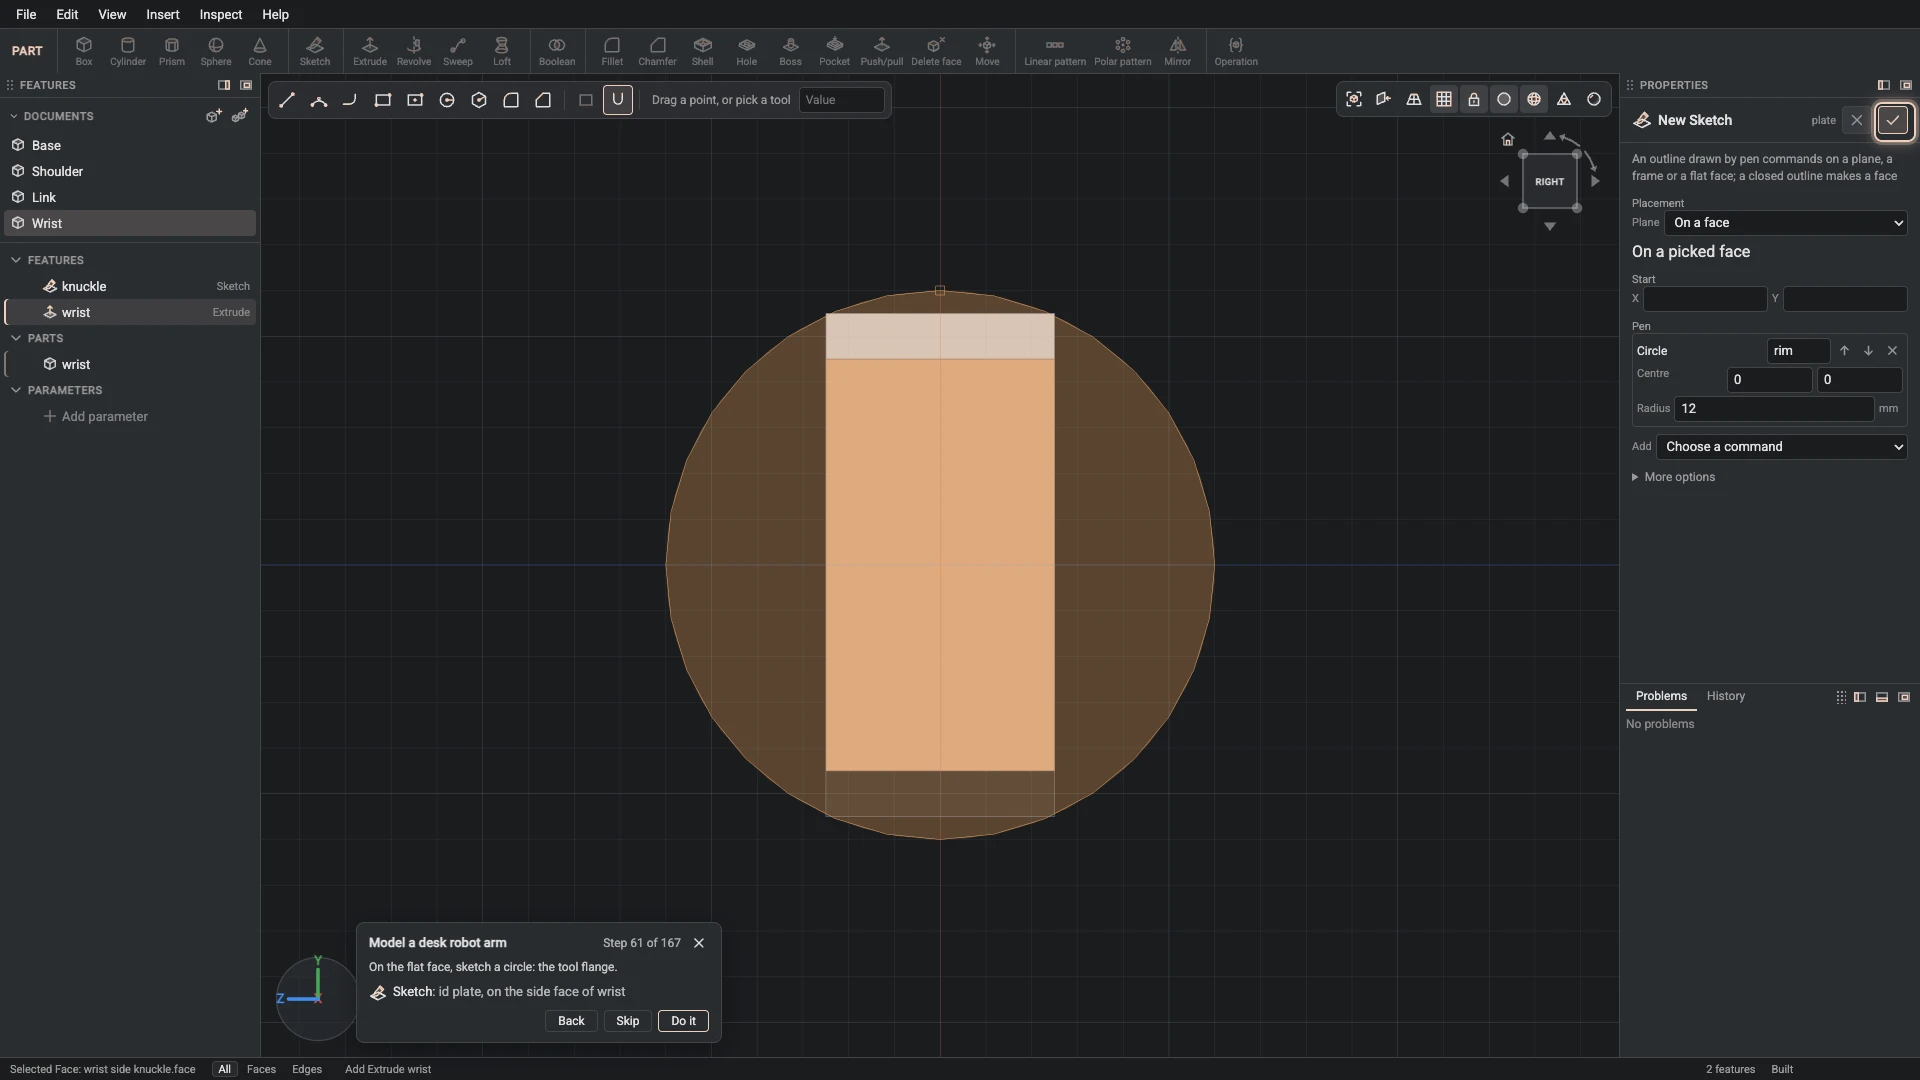
Sketch, from Insert > Sketch: id plate, on the side face of wrist.
On the flat face, sketch a circle: the tool flange.
-
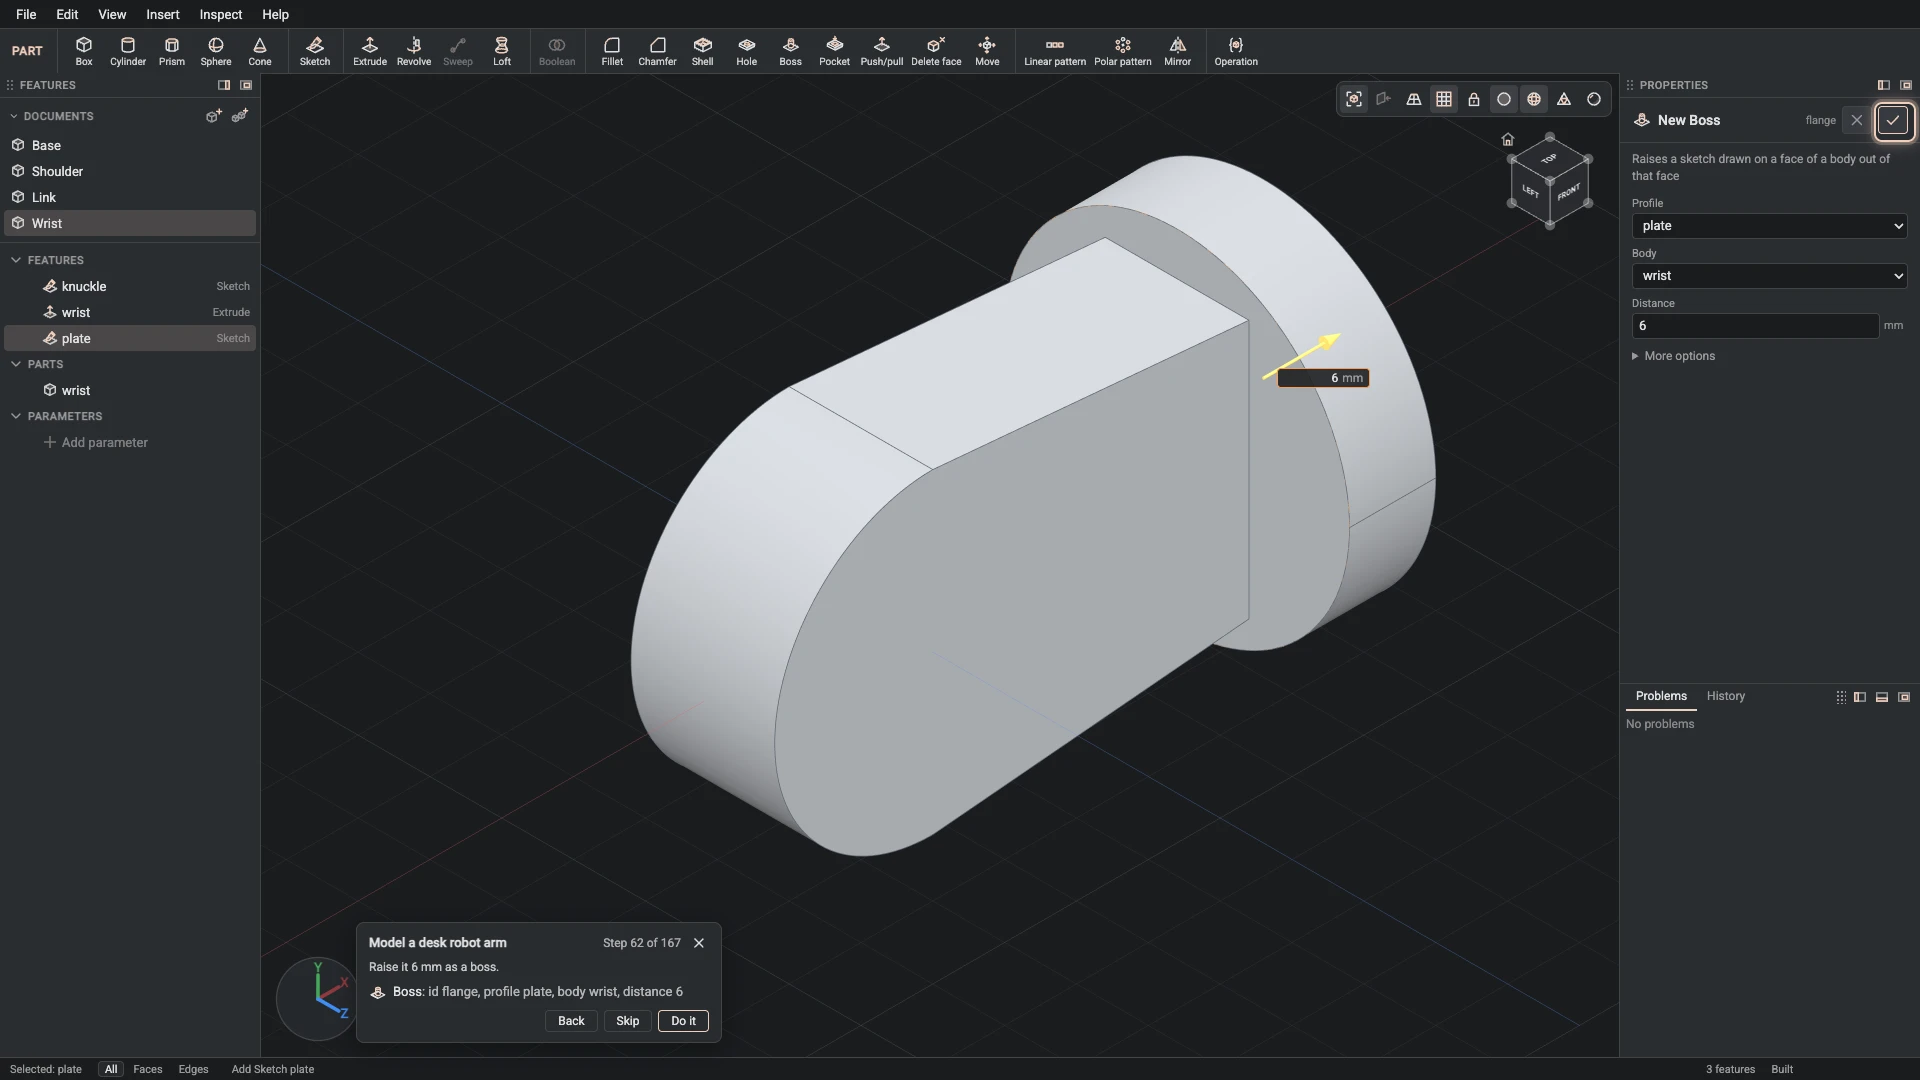
Boss, from Insert > Boss: id flange, profile plate, body wrist, distance 6.
Raise it 6 mm as a boss.
-
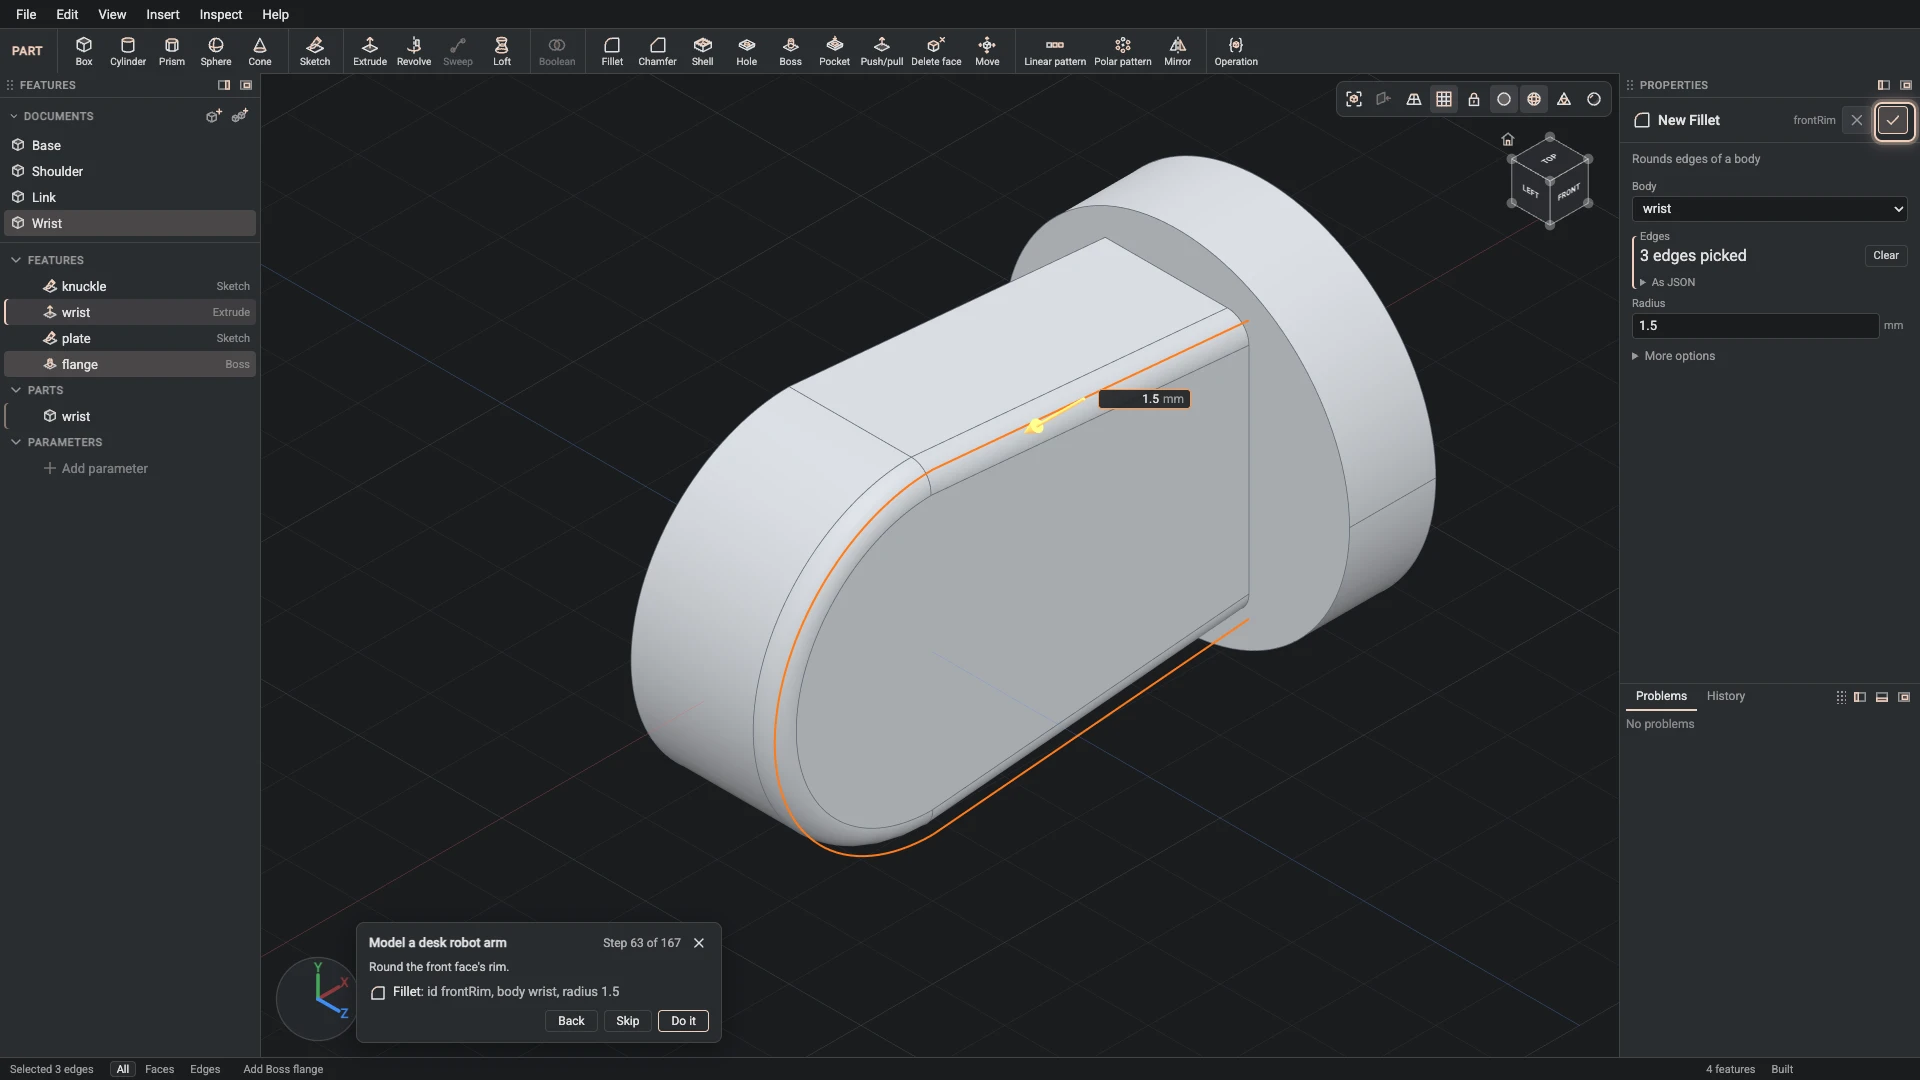
Fillet, from Insert > Fillet: id frontRim, body wrist, radius 1.5.
Round the front face's rim.
-
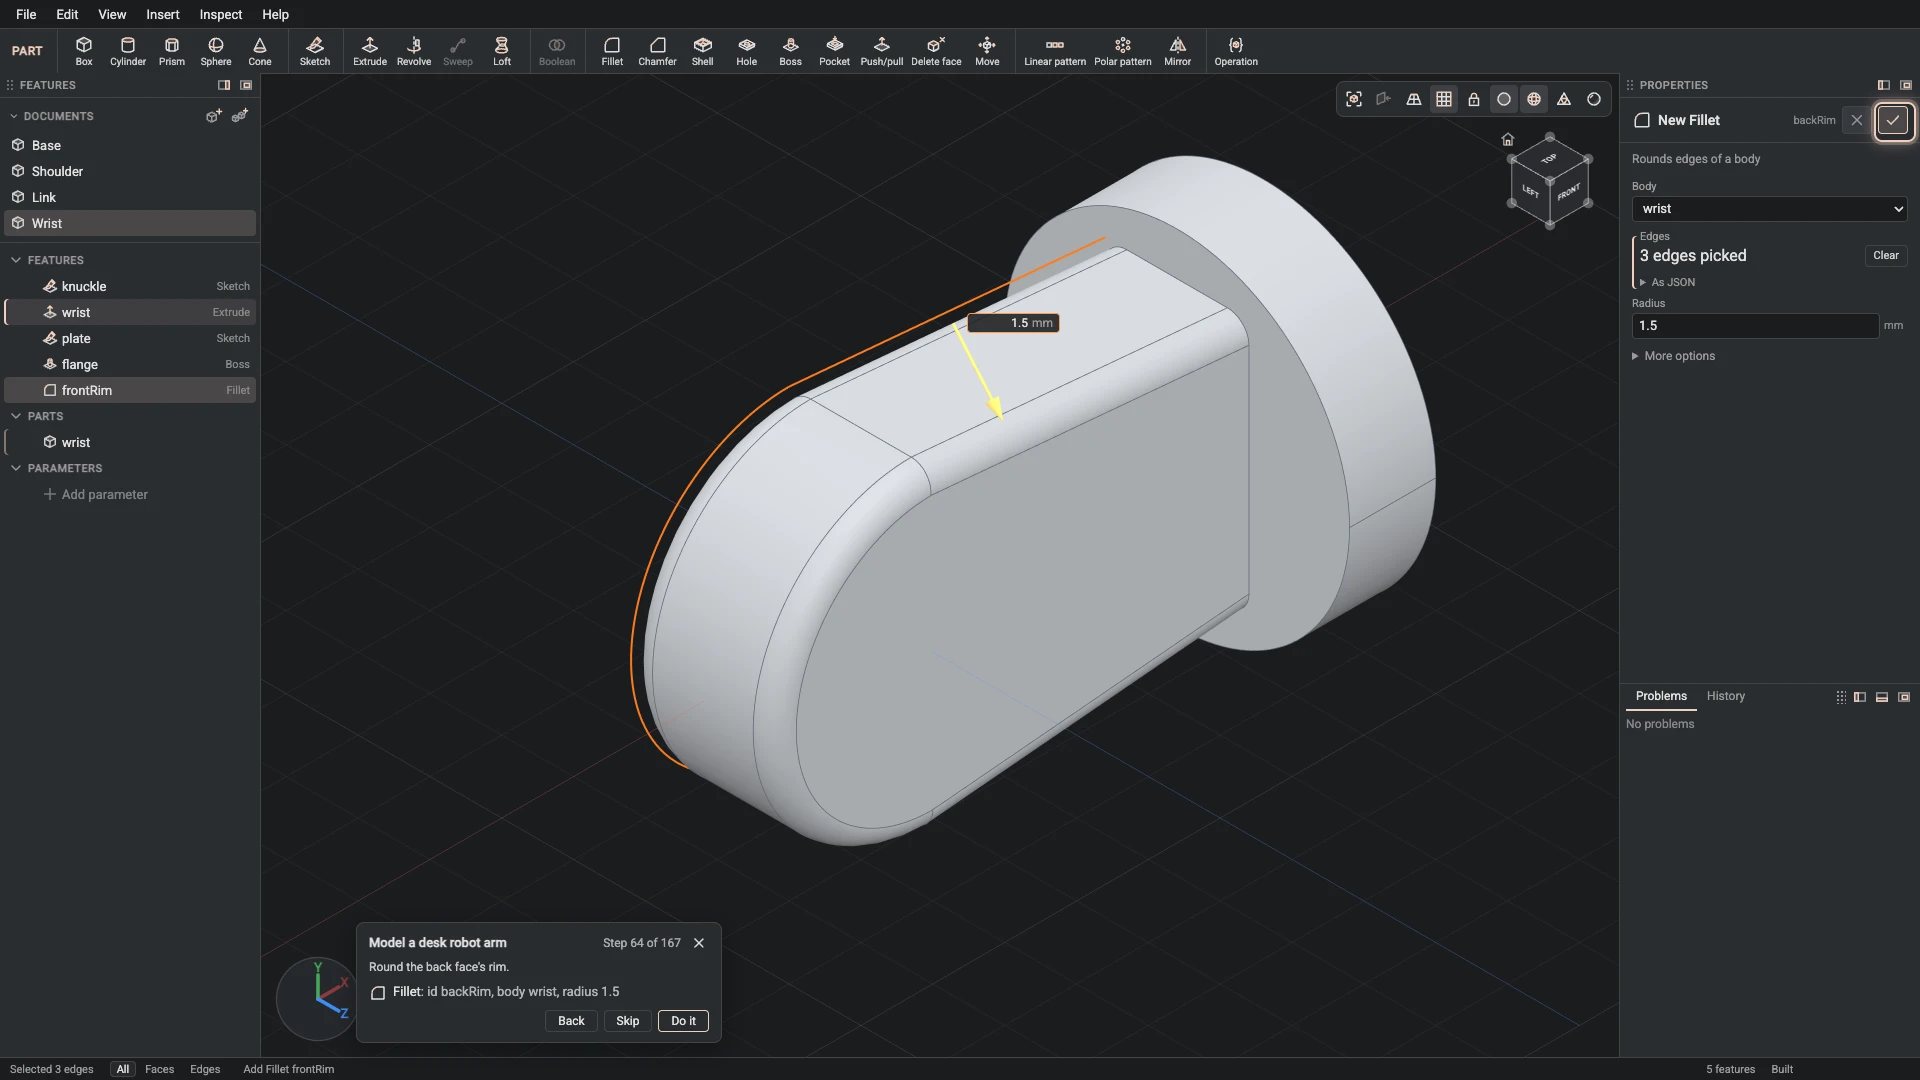
Fillet, from Insert > Fillet: id backRim, body wrist, radius 1.5.
Round the back face's rim.
-
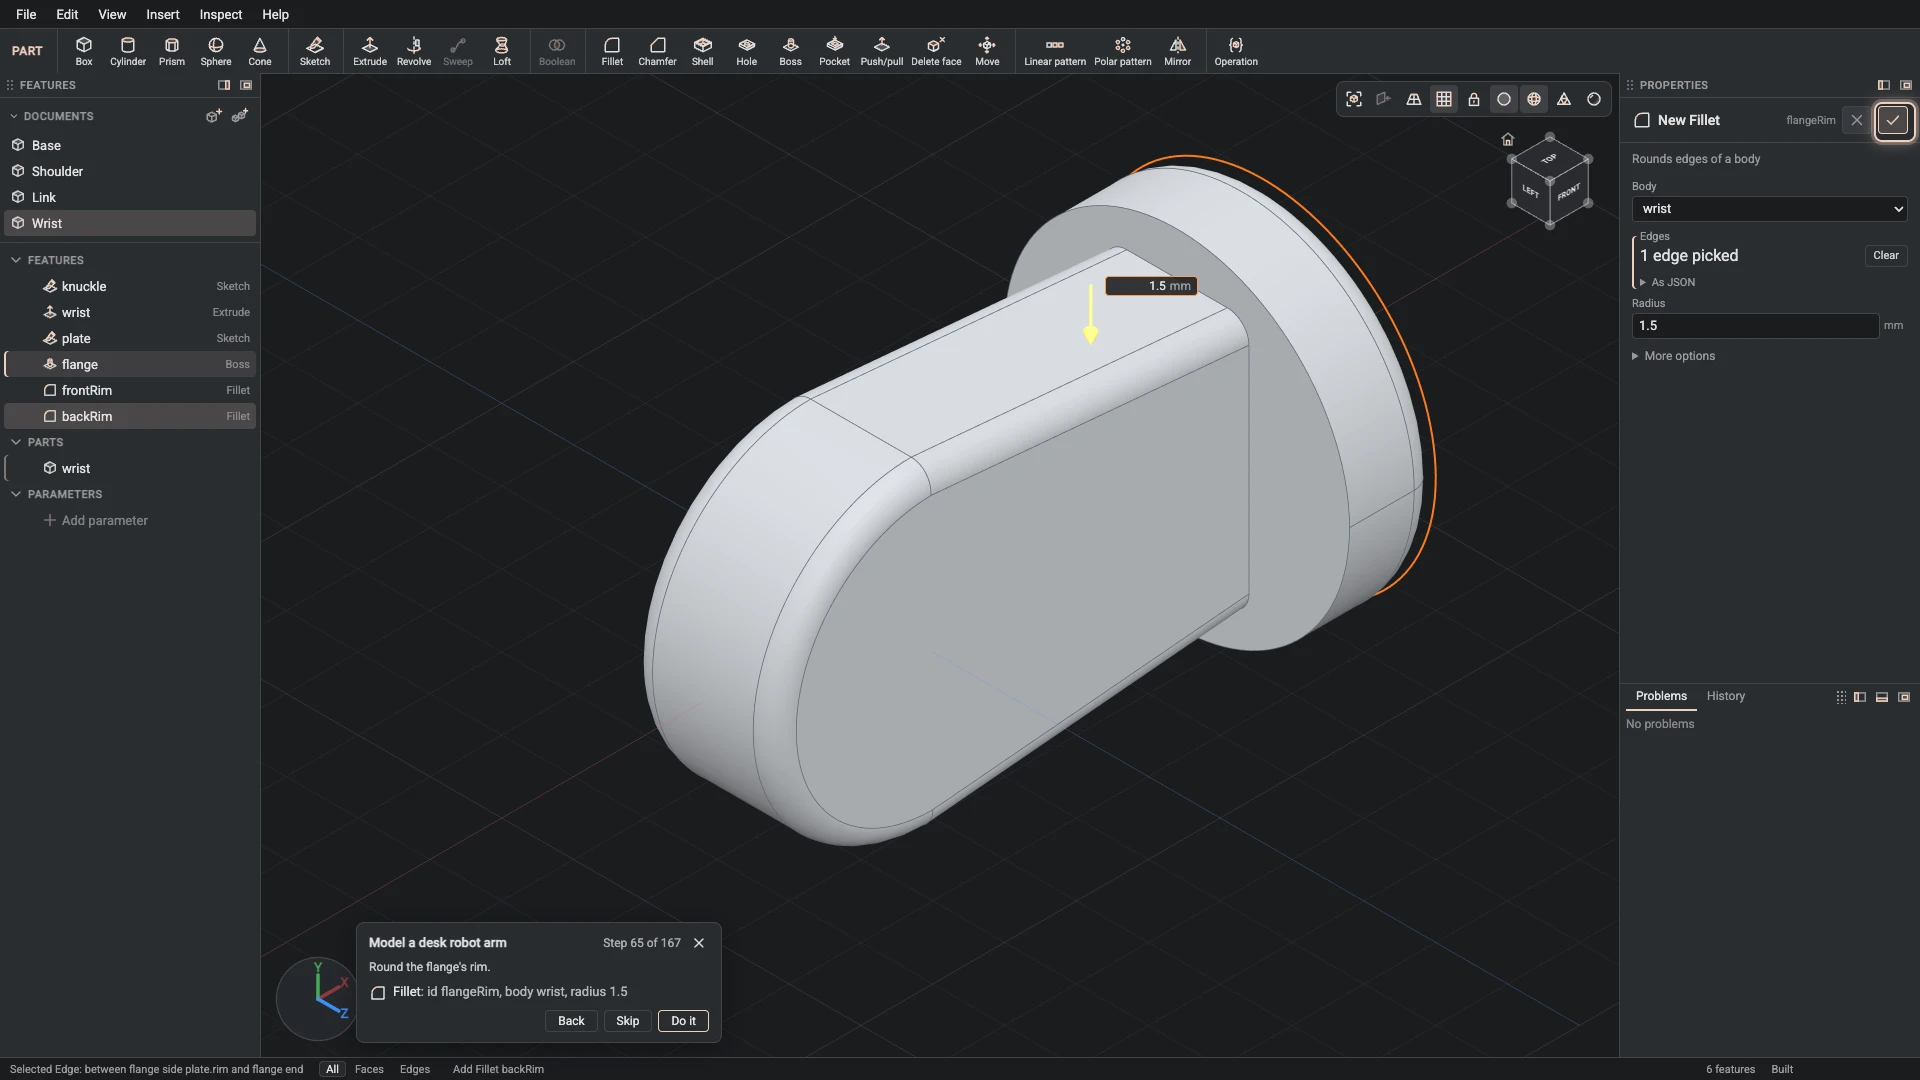
Fillet, from Insert > Fillet: id flangeRim, body wrist, radius 1.5.
Round the flange's rim.
-
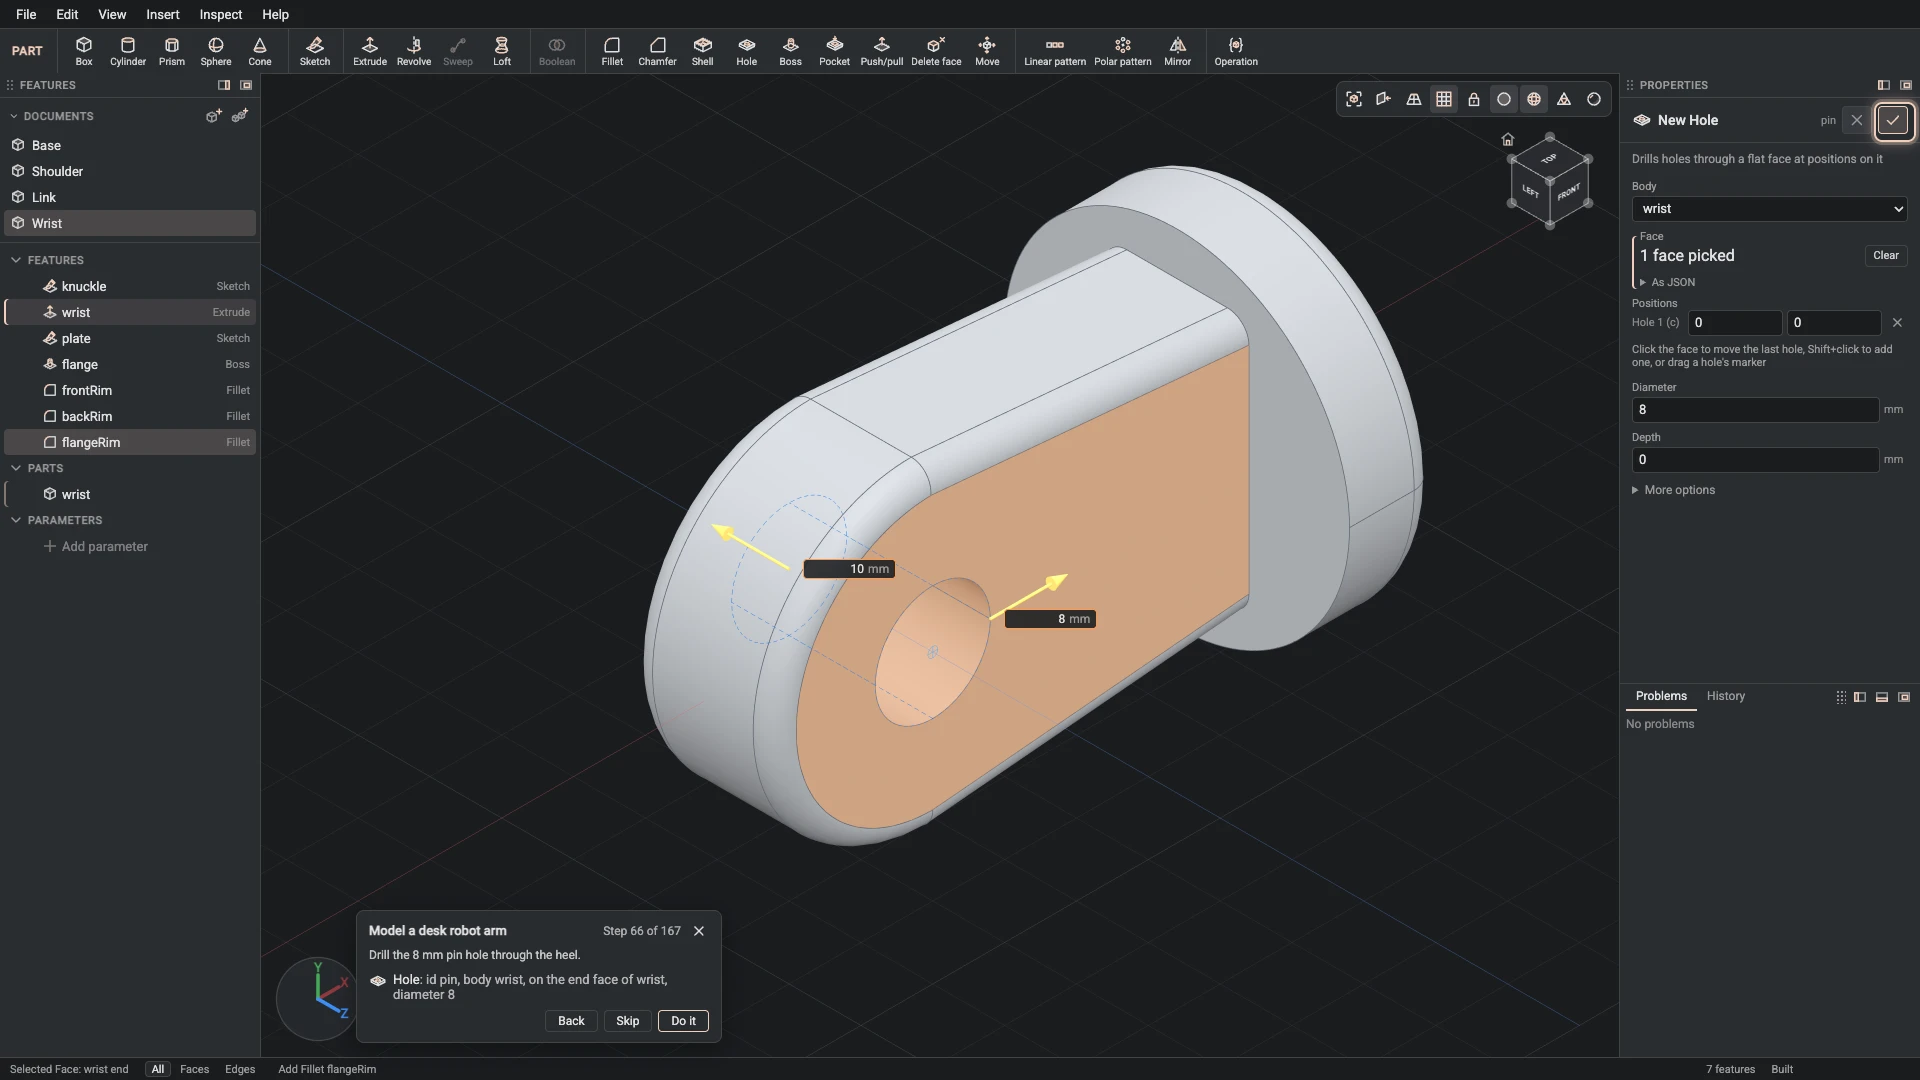
Hole, from Insert > Hole: id pin, body wrist, on the end face of wrist, diameter 8.
Drill the 8 mm pin hole through the heel.
-
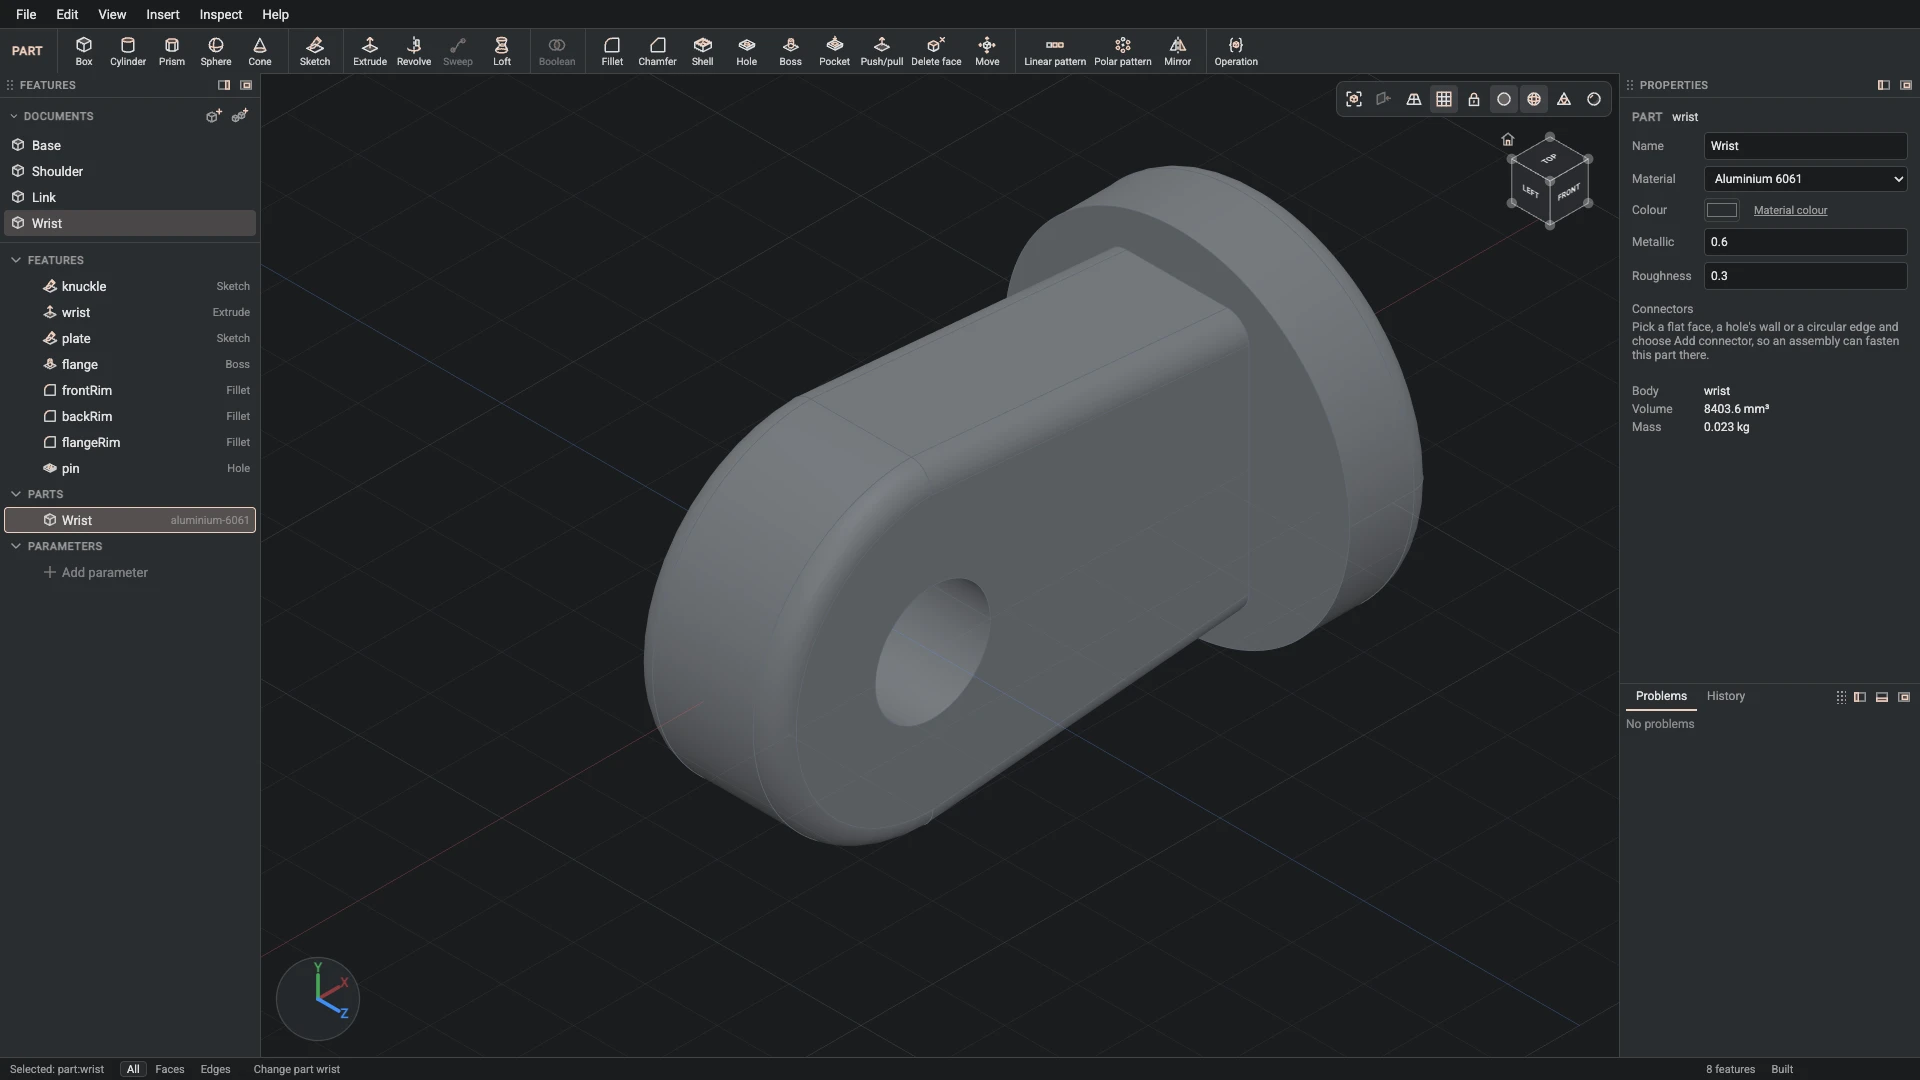
Part properties, from the Properties panel: id wrist, name Wrist, material aluminium-6061, color #2a2d31, metallic 0.6, roughness 0.3.
Name the part Wrist: dark anodised aluminium, like the base.
-
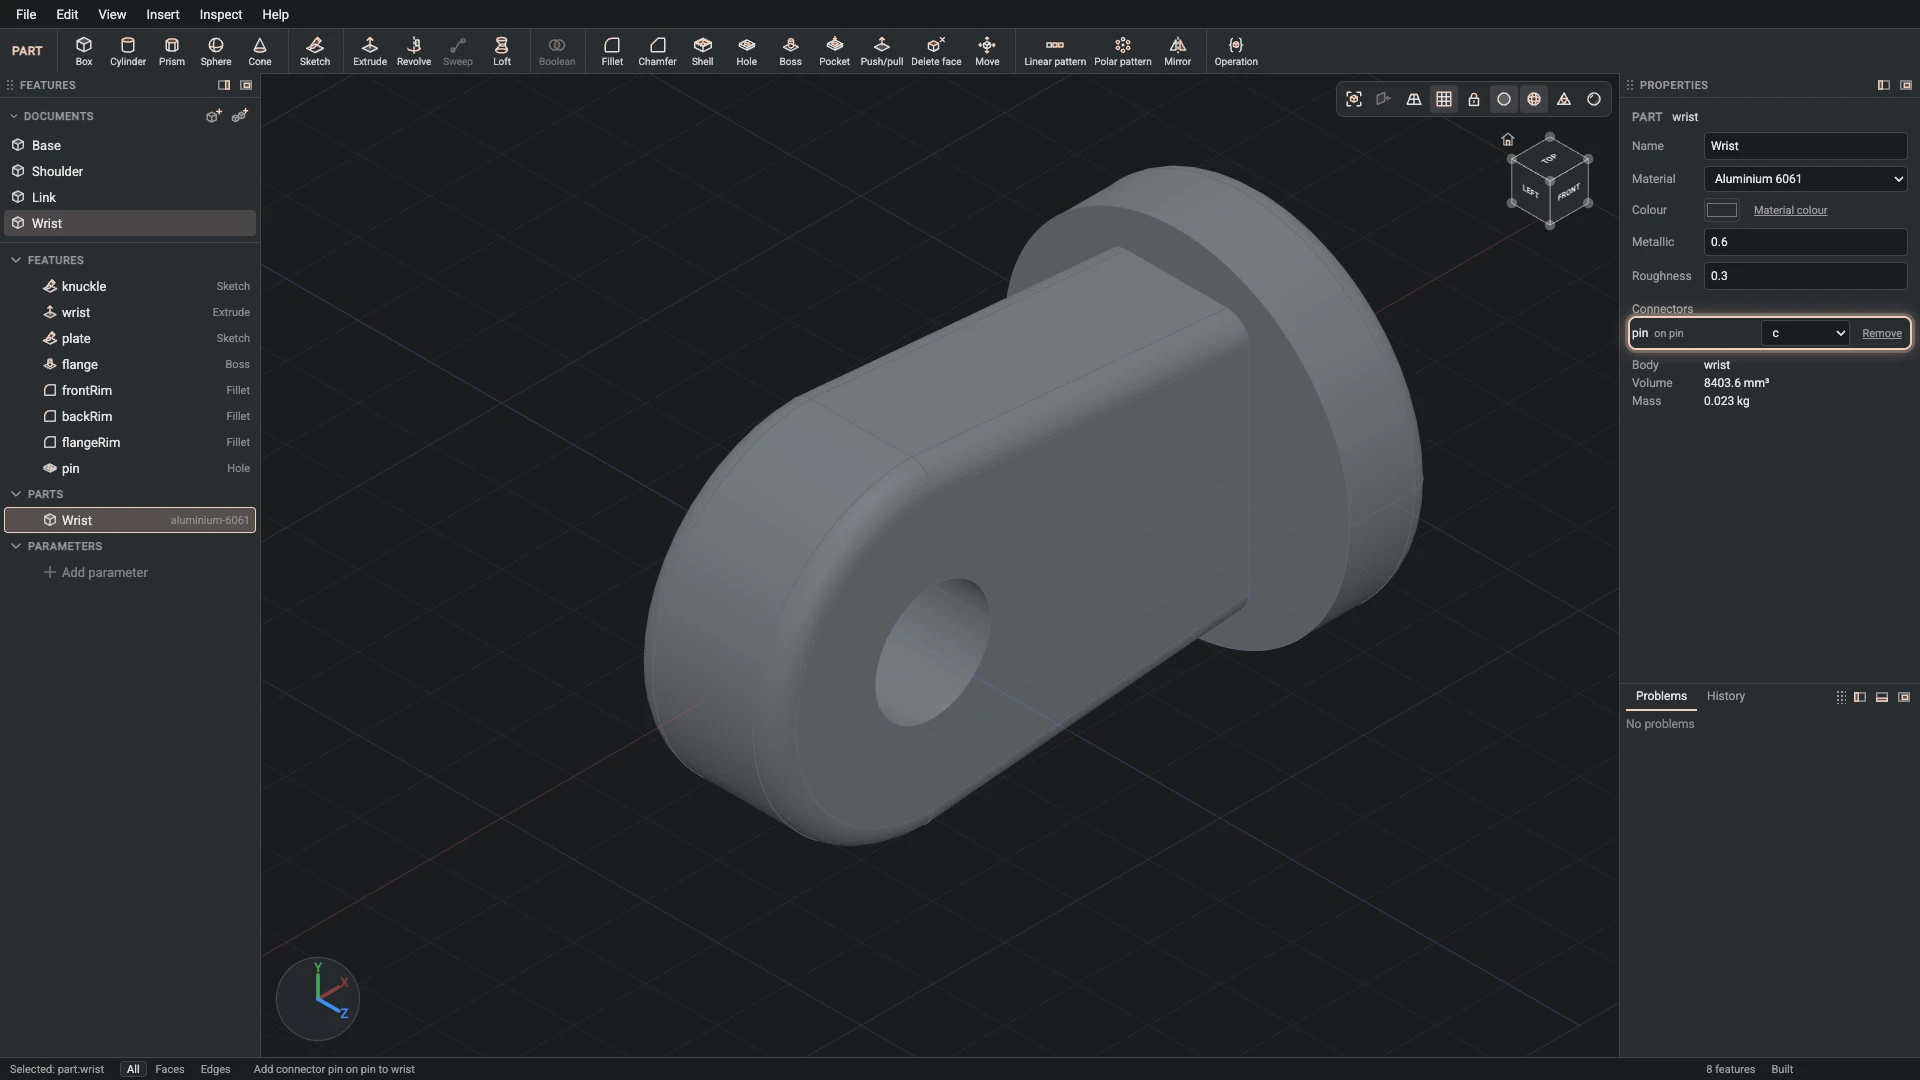
Add connector, from Insert > Add connector: part wrist, id pin, on the start face of wrist, axis the wall face of pin.
Add a connector on the back face, its axis through the pin hole. The wrist turns about it in the forearm's fork.
-
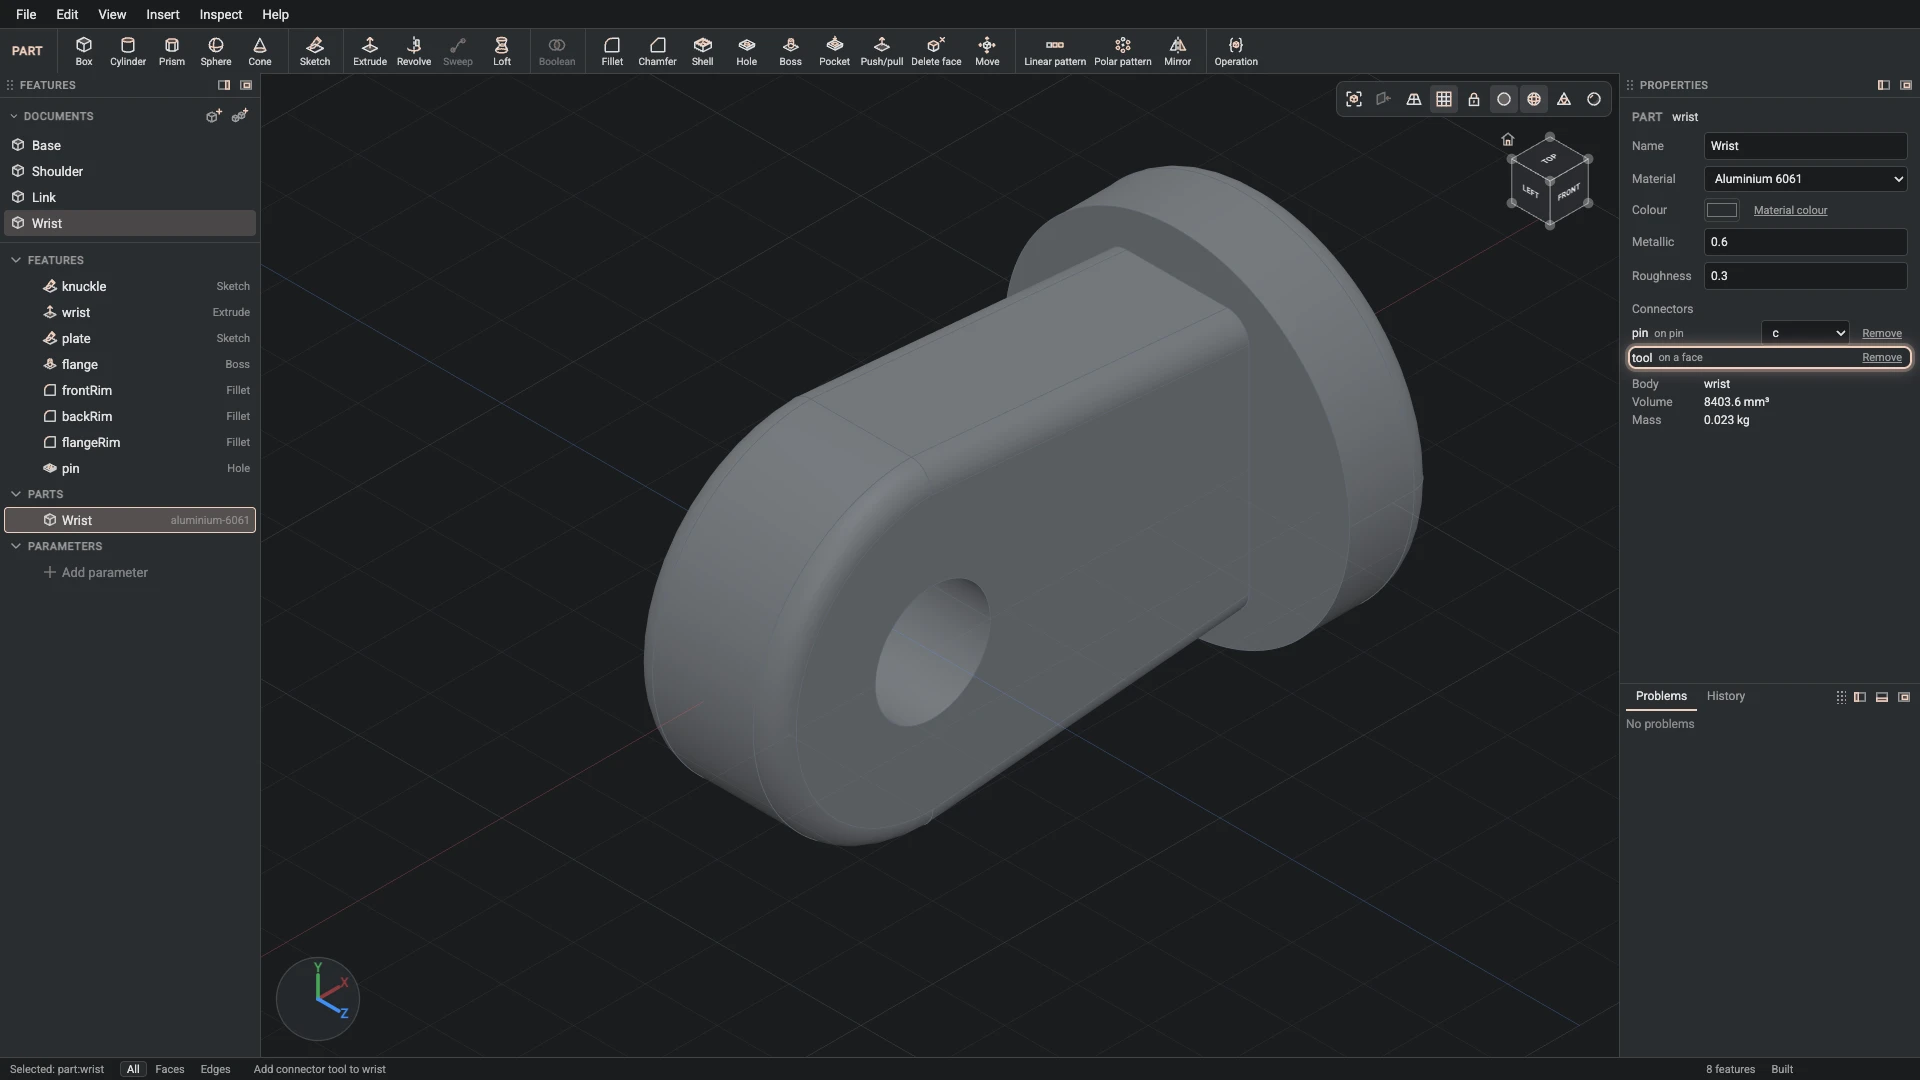
Add connector, from Insert > Add connector: part wrist, id tool, on the end face of flange.
Add a connector on the flange's face. Whatever the arm carries is fastened there.
Verified against the product in October 2026